
QJR6-2100 Six-axis robotic arm (manipulator)
6kg / 2121mm
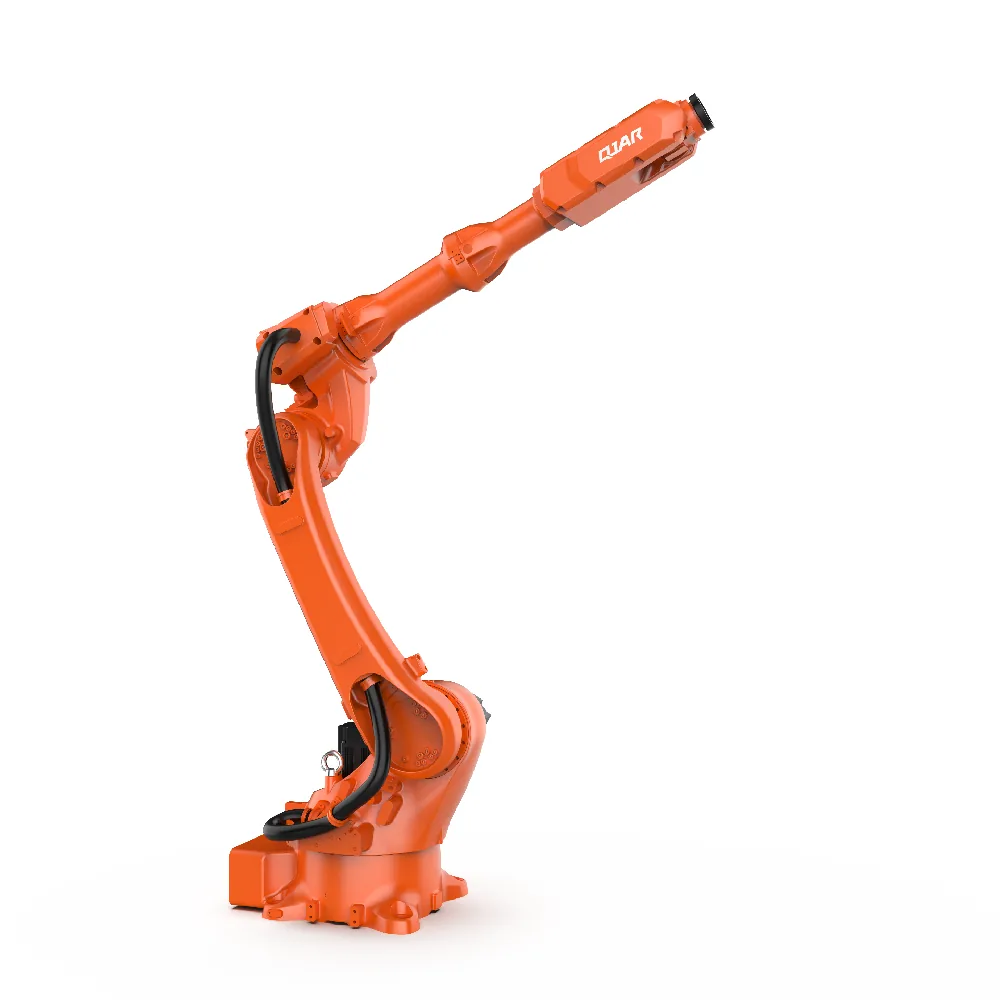
QJR6-2100 Specifications
QJR6-2100 industrial robot, payload 6kg, with an armspan of 2121mm.
Arc Welding Series Robots (H/Welding Model) · Series technical features
4-10kg · Hollow Arm · Welding main force
Official product features: hollow structure with arms and wrists, built-in welding cable, suitable for welding in narrow spaces.
After installing the fuselage cover, it can be used in harsh environments.
Multiple armspans from 1400mm to 2100mm matched tooling layouts.
2024 Public News: 800 welding robots serve Honglu Steel Structure.
Arc Welding Series Robots (H/Welding Model) · Other models in the same series
Compare load and reach to choose the model that best suits your process.
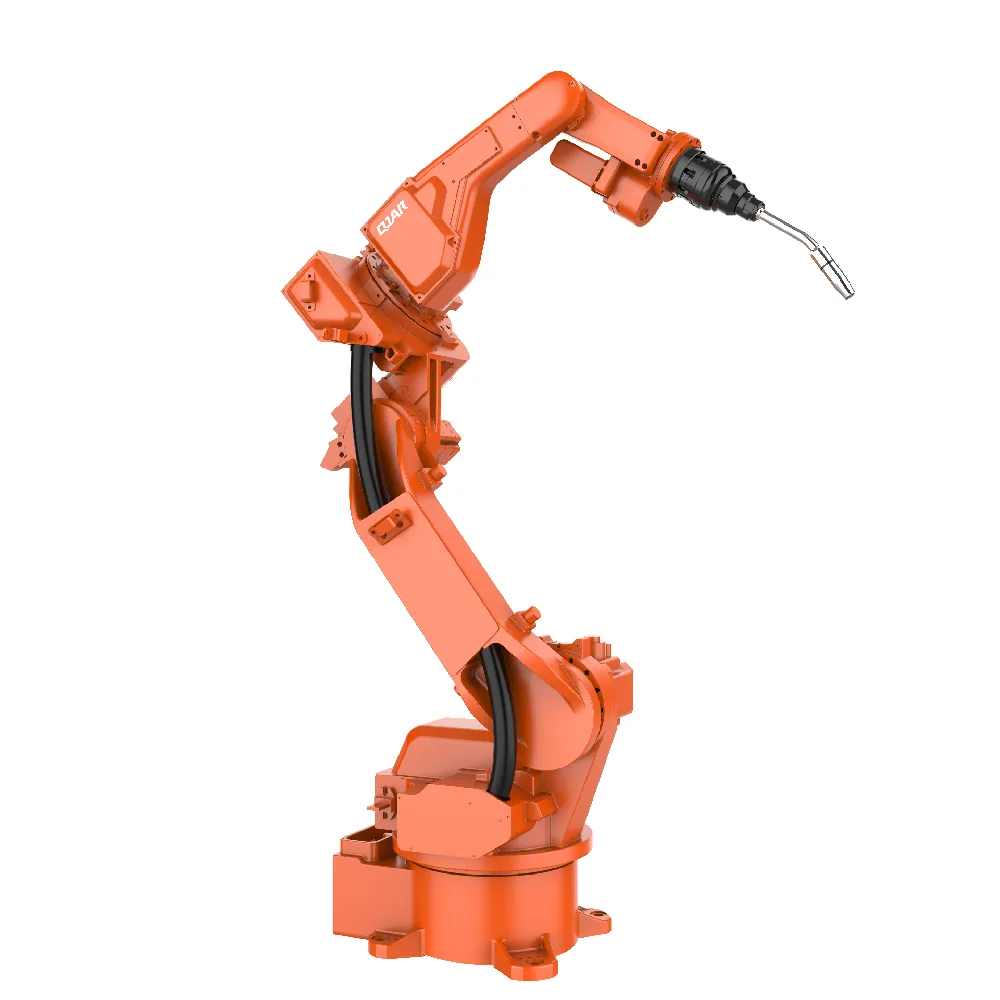
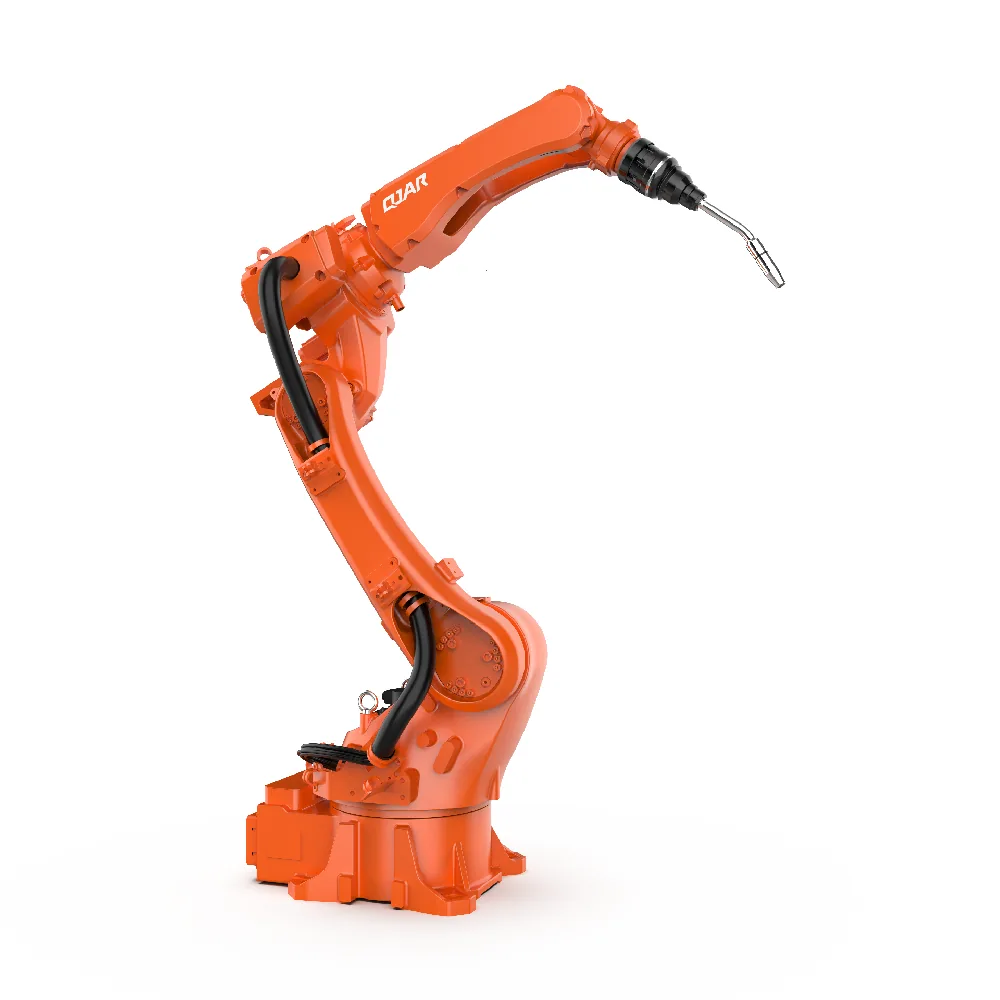
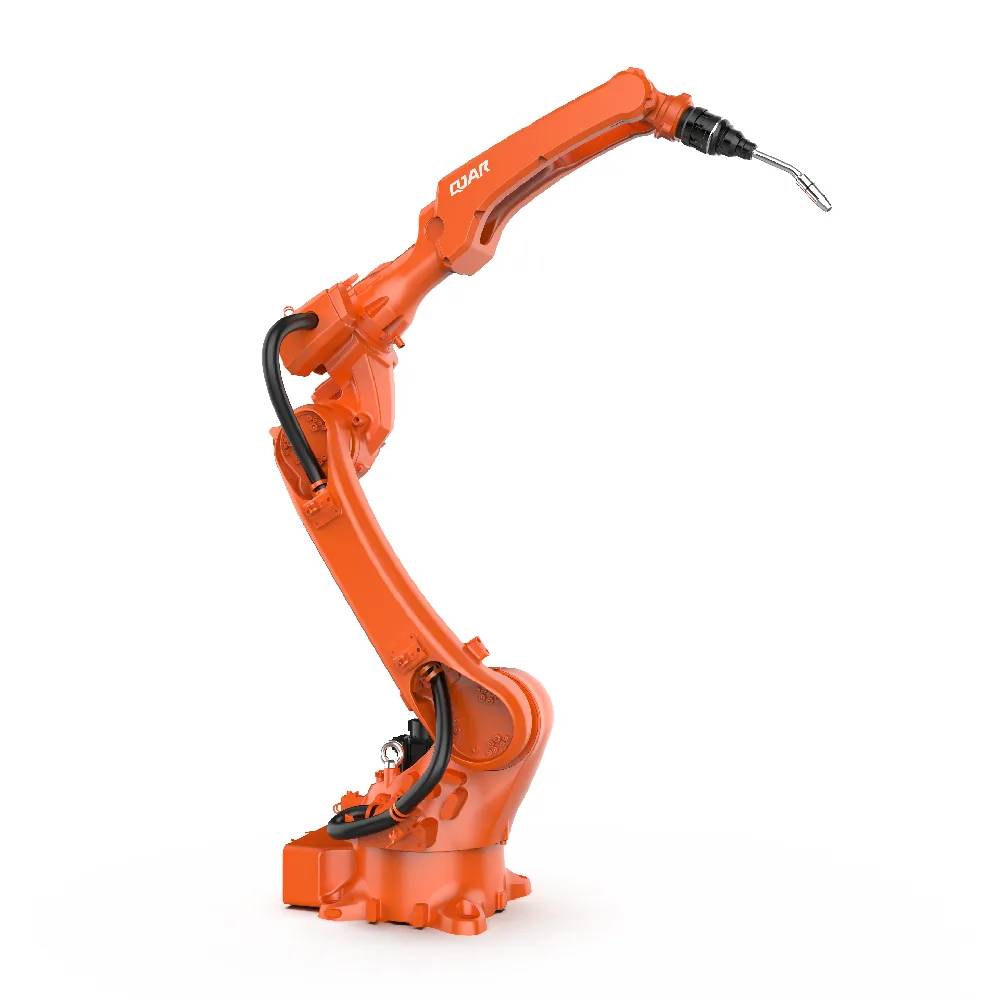
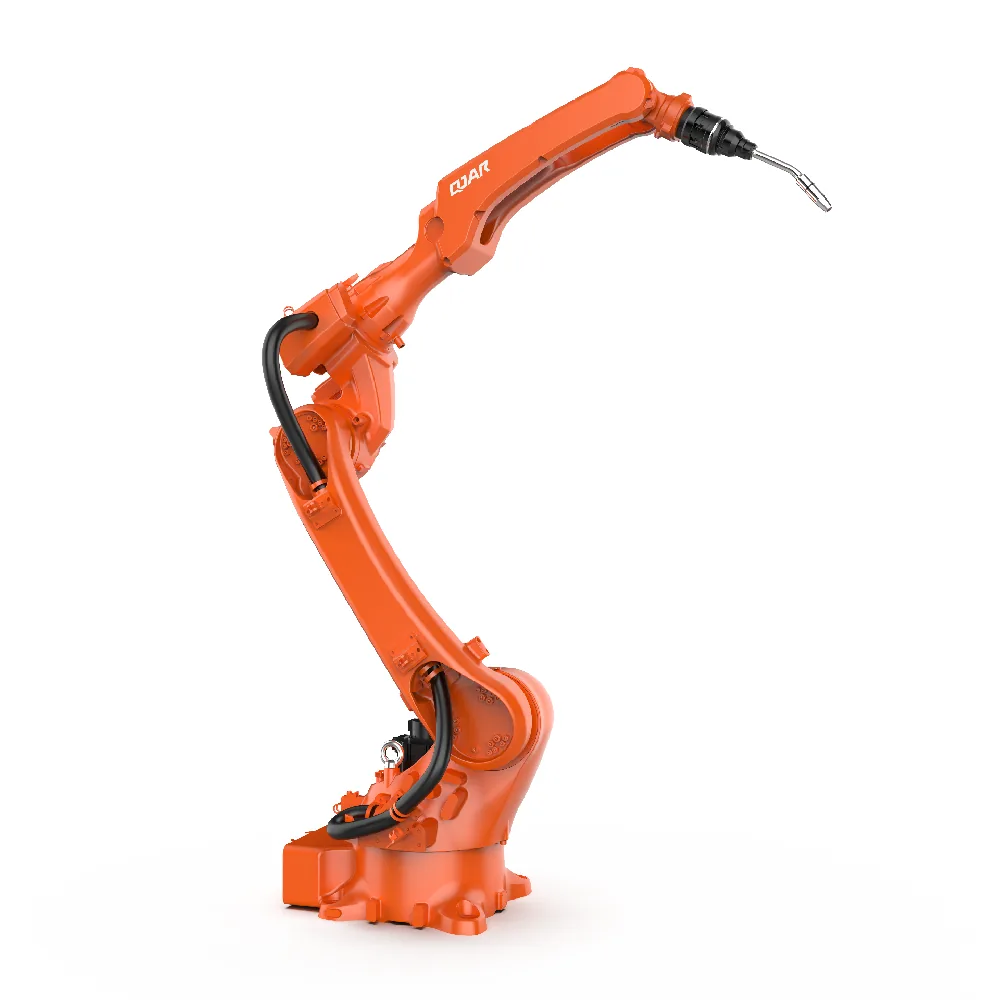
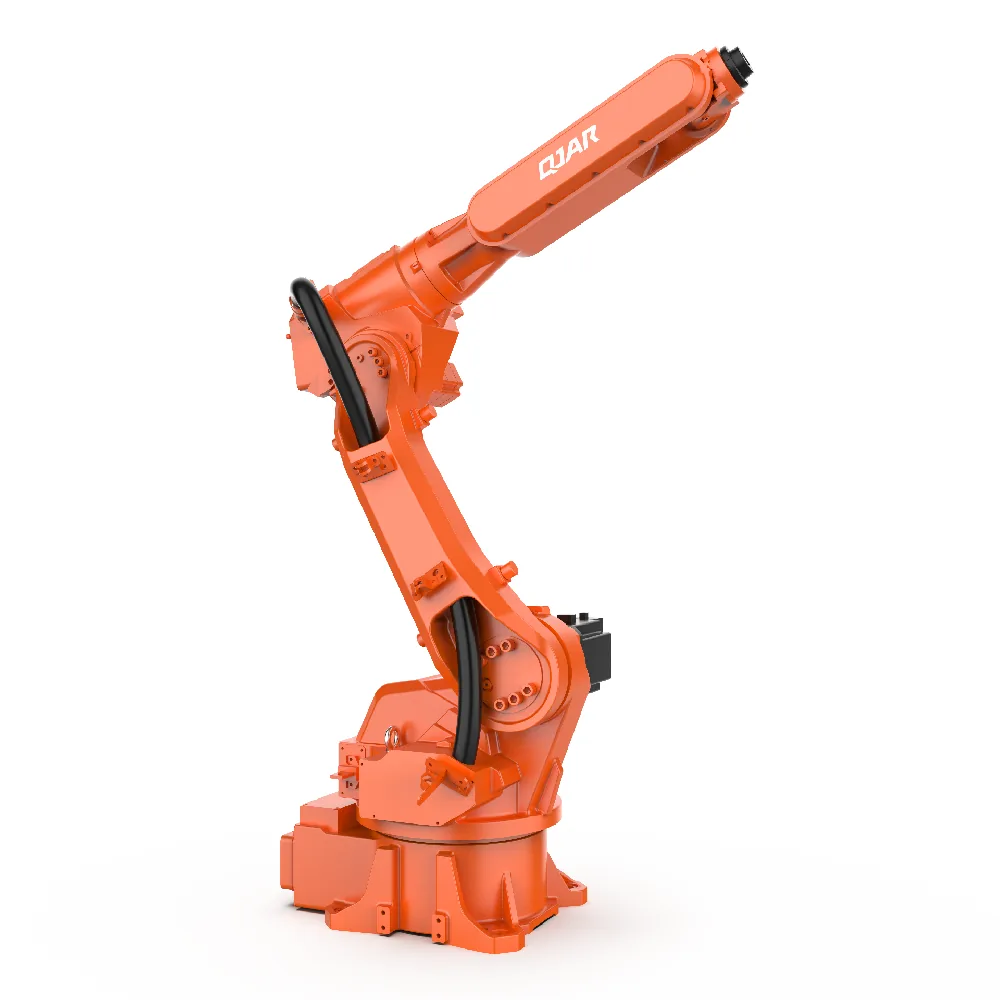
QJR6-2100 model positioning and working condition adaptation
QJR6-2100 This is an industrial robot model belonging to QJAR Robotics' arc welding series (H/welding version), with a rated load of 6kg, a motion radius of 2121mm, and a repeatability of ±0.05mm. QJAR Robotics' technical foundation is based on the background of QJAR motorcycle equipment manufacturing, with the QJR series focusing on welding and general handling both for its cost-effectiveness. The control platform is the QJAR Controller (QJR platform), and the program ecosystem consists of graphical programming + welding process packages.
From the perspective of working condition adaptation, the typical use for lightweight load (6kg) positioning is:Machine tool loading and unloading, 3C assembly, inspection, and handling of small and medium-sized parts。 The long reach (2121mm) covers multiple stations and large pallets, reducing robot movement or coordination with ground track expansion. ± 0.05mm repeatability is the standard level for six-axis industrial robots, covering most working conditions such as welding, handling, palletizing, and loading/unloading. The end fixture is counted as a load from the most important point—the total of gripper + workpiece + sensor should not exceed 80% of the rated value. Workpieces with high inertia (long rod/uneven load) should be checked separately.
| Parameters | Engineering interpretation and usage recommendations |
|---|---|
| Rated load: 6kg | It is recommended to reserve a load margin of 20%–30%; Verification is made by combining end self-weight + workpiece + imbalanced load inertia, especially sensitive to high-speed conditions |
| Movement radius: 2121mm | Determine the radius of the workcell layout: bins, tooling, and fences are bounded by maximum arm span + safety distance; Verify the accessibility of each pick-and-place point during cross-station service |
| Repeatability: ±0.05mm | Repeatability ≠ absolute accuracy: Precision assembly requires external measurement closed-loop or visual guidance; Long-term accuracy trends rely on annual retest management |
| Controller: QJAR Controller (QJR platform) | Decide on the process ecosystem, spare parts channels, and second-hand residual value; Currently, spare parts channels are smooth, and repair and upgrade paths are mature |
Control systems and common failure modes
The QJAR controller (QJR platform) controller is compatible with the QJR6-2100, with a programming language and development environment of graphical programming + welding process package. Maintenance of this generation of control platforms focuses on three basic components: power, storage, and cooling—most "sudden downtime" can be detected in advance when preventive maintenance is in place.
| Failure mode | Typical performance | Disposal recommendations |
|---|---|---|
| Driver overcurrent alarm | Driver overcurrent alarm | Included as a mandatory inspection item for annual maintenance, with spare parts stocked in advance |
| Encoder cable interference | Encoder cable interference | Initial interpretation of alarm codes by reference with manuals, remote diagnosis allows for early positioning |
| Welding process parameter drift | Drift of welding process parameters (welding machine linkage) | Daily inspection coverage, with abnormal trends (abnormal noises/temperature rise/errors) recorded |
| Showing the wear and tear of the teaching device | Showing the wear and tear of the teaching device | Quarterly dust removal maintenance and cabinet temperature monitoring |
| Maintenance projects | Cycle recommendations | Key points |
|---|---|---|
| Batteries should be replaced periodically | By cycle | Batteries should be replaced periodically |
| Welding linkage parameters should be regularly calibrated | Periodically | Welding linkage parameters should be regularly calibrated |
| Reducer lubrication management | According to the manufacturer's manual cycle | Reducer lubrication management |
| Cable and drag chain inspection | every six months | Insulation, shielding, and bending radius inspection of power and encoder lines, as well as wear of cables inside the drag chain, are the main causes of intermittent faults |
| Zero point and accuracy retest | Every year | Repeatability measured by dial gauges or laser trackers, drift trend digitization—accuracy degradation can be seen six months in advance |
| Control cabinet dust removal and fans | Every quarter | Filter cleaning, fan speed and noise checks, cabinet temperature recording; Dust environments shorten the cycle |
Henghuan's service capabilities for the QJR6-2100
This site is a third-party robotics technology service provider. The QJR6-2100 supports eight major business services as follows (sorted by service frequency for each model):
- Maintenance and repairFor on-site diagnostics, board-level repairs, and annual maintenance contracts for QJR6-2100—battery replacement periodically, we follow SOPs and respond to Sichuan-Chongqing on the same day.
- Used & in-stock robot sales: Affordable second-hand prices, budget choice for welding and handling conditions; Perform full-axis precision inspection before purchasing; The QJR6-2100 or equivalent models in the inventory come with a full-function test report and a 12-month warranty.
- Sales of new industrial robots: When adding new production lines or replacing entire batches, we conduct cross-brand selection comparisons based on process requirements (including models of the same class as QJAR Robotics), and provide configuration and pricing plans.
- Applied technology services: Process programming, trajectory optimization, tap time tapping, and model change formula management for the QJR6-2100 are targeted for machine tool loading and unloading, 3C assembly, inspection, and small and medium-sized parts handling conditions.
- Research and development of automation equipment: Custom fixture ends, peripheral tooling, and safety fences for QJR6-2100, with interfaces designed according to QJAR Robotics flange and IO standards.
- Robot rental: For short-term capacity or process validation periods, QJR6-2100 equivalent in-stock models can be rented, including transportation, installation, and commissioning; rental period is flexible and can be repurchased.
Common issues with this device
Q: Is it easy to find spare parts for the JR6-2100?
QJAR Robotics: Spare parts channels for this generation are smooth; we have in-stock or short-cycle channels for standard parts such as drivers, power modules, batteries, and teach pendant components; It is recommended to configure consumables for battery replacement periodically according to the annual maintenance contract.
With a nominal load of 6kg, how much weight can it actually handle?
The rated load is the static load limit of the flange surface. In actual selection, three factors must be considered: the self-weight of the end fixture (vacuum suction cup groups or grippers often account for 2–5kg), the inertia generated by the workpiece offload (checked according to the inertia ratio when the center of gravity deviates from the flange center), and the dynamic load during high-speed movement. The conventional engineering practice is to keep the "end + workpiece" within 70%–80% of the rated value to ensure cycle time and service life.
If the equipment's accuracy deteriorates after several years of use, how can it be restored?
According to the inspection order: first check whether the zero point is drifting (common after collision or battery depletion), then perform zero calibration; Check the reducer's return error (actual measurement of forward and reverse positioning deviation; if exceeded, disassemble or replace); Then check the installation base fastening and foundation settlement; Finally, trajectory compensation parameter restructuring. Most accuracy issues can be mostly restored after calibration and maintenance, so there is no need to rush into major repairs—we first release the inspection data before deciding on the plan.
Is the used QJR6-2100 worth buying?
Affordable second-hand prices, budget-friendly options for welding and handling conditions; Perform full-axis precision inspection before purchasing. Three essential items for second-hand procurement: comprehensive inspection reports (axial accuracy, driver status, insulation and battery), maintenance history and operating hours, controller generation, and software license integrity. Every used machine we sell comes with inspection records and a 12-month warranty, and we can also accept third-party inspections designated by customers.
Need technical support or procurement for this model?
Whether it's model selection comparison, installation and commissioning, or maintenance of in-use equipment, you can contact Henghuan. Tell us about your processes, loads, and equipment status, and we will provide third-party technical support and solution recommendations.
Contact Henghuan Back to the full series